About Me
Hello! I am a PhD student at Stanford University in the Department of Civil and Environmental Engineering. I am a researcher in the Engineering Informatics Group under Professor Kincho Law.
Email: satomm@stanford.edu
Research Interests
I am broadly interested in computing in engineering. My PhD research is primarily in robotics and manufacturing, applying machine learning and quantum computing to real-world physical systems. My work spans perception and socially-aware navigation for human-centric multi-robot systems, as well as melt pool prediction and anomaly detection in laser powder bed fusion (LPBF) additive manufacturing. I enjoy working with hardware and integrating software along the entire hardware stack (from microcontrollers to edge devices to the cloud). Recently, I've been exploring the use of near-term (NISQ-era) quantum computing for practical, deployable solutions for additive manufacturing and robotics applications.
Education
- PhD, Civil and Environmental Engineering, Stanford University (Expected 2027)
- MS, Electrical Engineering, Stanford University (2025)
- MS, Civil and Environmental Engineering, Stanford University (2023)
- BE, Civil Engineering and Mathematics, Vanderbilt University (2021)
Publications
- M. Sato and K. Law, “LPBF Melt Pool Prediction Using Quantum Computers and Machine Learning,” 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), Toronto, CAN, September 13–18, 2026. doi: 10.1109/QCE68830.2026.00362. [PDF]
- M. Sato and K. Law, “Socially Consistent Multi-Robot Navigation Using Decoupled Planning and Trajectory Coordination,” Civil Engineering Sciences, vol. 2, no. 25, September 2026, doi: 10.34133/cesci.0025.
- M. Sato and K. Law, “A Hybrid Quantum-Classical Approach for Melt Pool Prediction in Laser Powder Bed Fusion,” Proceedings of the ASME 2026 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Houston, TX, Aug. 23–26, 2026, doi: 10.48550/arXiv.2606.23719.
- M. Sato and K. Law, “A Mobile Robot Framework for Learning to Detect New Objects with Large Language Models,” J. Comput. Inf. Sci. Eng., vol. 26, no. 6, June 2026, doi: 10.1115/1.4071863.
- M. Sato and K. Law, “LPBF Melt Pool Prediction Using Quantum Computers and Machine Learning,” 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), Toronto, CAN, September 13–18, 2026. doi: 10.1109/QCE68830.2026.00362. [PDF]
- M. Sato and K. Law, “Socially Consistent Multi-Robot Navigation Using Decoupled Planning and Trajectory Coordination,” Civil Engineering Sciences, vol. 2, no. 25, September 2026, doi: 10.34133/cesci.0025.
- M. Sato and K. Law, “A Hybrid Quantum-Classical Approach for Melt Pool Prediction in Laser Powder Bed Fusion,” Proceedings of the ASME 2026 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Houston, TX, Aug. 23–26, 2026, doi: 10.48550/arXiv.2606.23719.
- M. Sato and K. Law, “A Mobile Robot Framework for Learning to Detect New Objects with Large Language Models,” J. Comput. Inf. Sci. Eng., vol. 26, no. 6, June 2026, doi: 10.1115/1.4071863.
- M. Sato and K. Law, “A Mobile Robot Framework for Learning to Detect New Objects with Large Language Models,” Proceedings of the ASME 2025 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Anaheim, CA, Aug. 17–20, 2025, doi: 10.1115/DETC2025-164474.
- M. Sato, V. Wong, H. Yeung, P. Witherell, and K. Law, “Identification and Interpretation of Melt Pool Shapes in Laser Powder Bed Fusion with Machine Learning,” Smart and Sustainable Manufacturing Systems, vol. 8, no. 1, Apr. 2024, doi: 10.1520/SSMS20230035.
- M. Sato, V. Wong, K. Law, H. Yeung, P. Witherell, “Explainability of Laser Powder Bed Fusion Melt Pool Classification Using Deep Learning,” Proceedings of the ASME 2023 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Boston, MA, Aug. 20–23, 2023, doi: 10.1115/DETC2023-109137.
- M. Sato, V. Wong, K. Law, H. Yeung, Z. Yang, B. Lane, and P. Witherell, “Anomaly Detection of Laser Powder Bed Fusion Melt Pool Images Using Combined Unsupervised and Supervised Learning Methods,” Proceedings of the ASME 2022 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, St. Louis, MO, Aug. 14–17, 2022, doi: 10.1115/DETC2022-88313.
- P. Nath, M. Sato, P. Karve, and S. Mahadevan, “Multi-fidelity Modeling for Uncertainty Quantification in Laser Powder Bed Fusion Additive Manufacturing,” Integrating Materials and Manufacturing Innovation, vol. 11, no. 2, pp. 256–275, 2022, doi: 10.1007/s40192-022-00260-9.
- B. Kapusuzoglu, P. Nath, M. Sato, S. Mahadevan, and P. Witherell, “Multi-Objective Optimization Under Uncertainty of Part Quality in Fused Filament Fabrication,” ASCE-ASME J Risk and Uncert in Engrg Sys Part B Mech Engrg, vol. 8, no. 1, Jan. 2022, doi: 10.1115/1.4053181.
- B. Kapusuzoglu, M. Sato, S. Mahadevan, and P. Witherell, “Process Optimization Under Uncertainty for Improving the Bond Quality of Polymer Filaments in Fused Filament Fabrication,” Journal of Manufacturing Science and Engineering, vol. 143, no. 2, Oct. 2020, doi: 10.1115/1.4048073.
Featured Projects
Autonomous Mobile Robot
Explore my open source autonomous mobile robot project. The project includes the robot's mechanical, electrical, and software design.
View Autonomous Mobile Robot Project →
Light Switch Presser
Detects when the office light turns off and swings an arm to hit the switch back on.
View Light Switch Presser Project →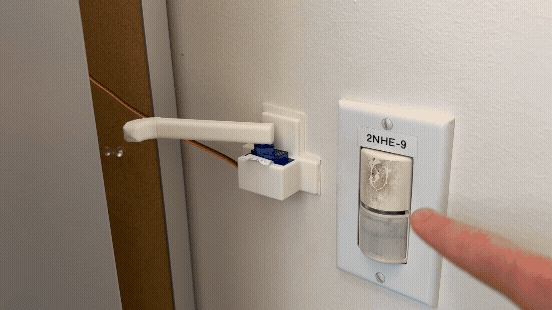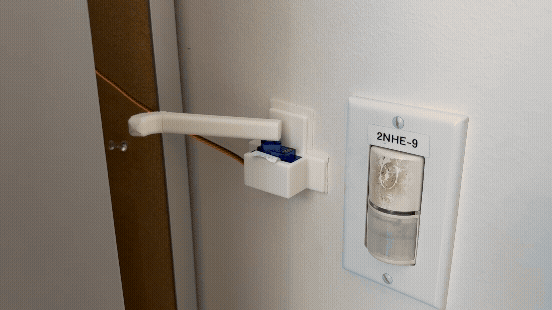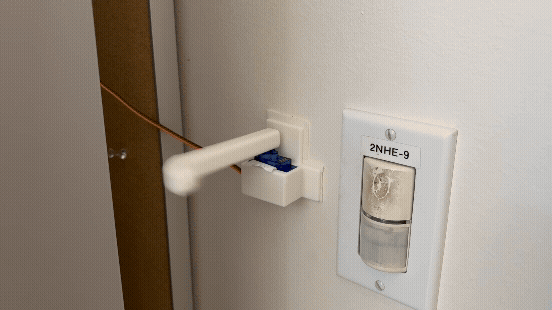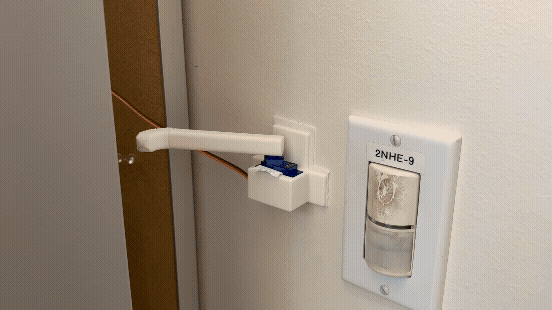
ME218C Final Project
Remote controlled boat for final project of Stanford ME218C course.
View ME218C Final Project →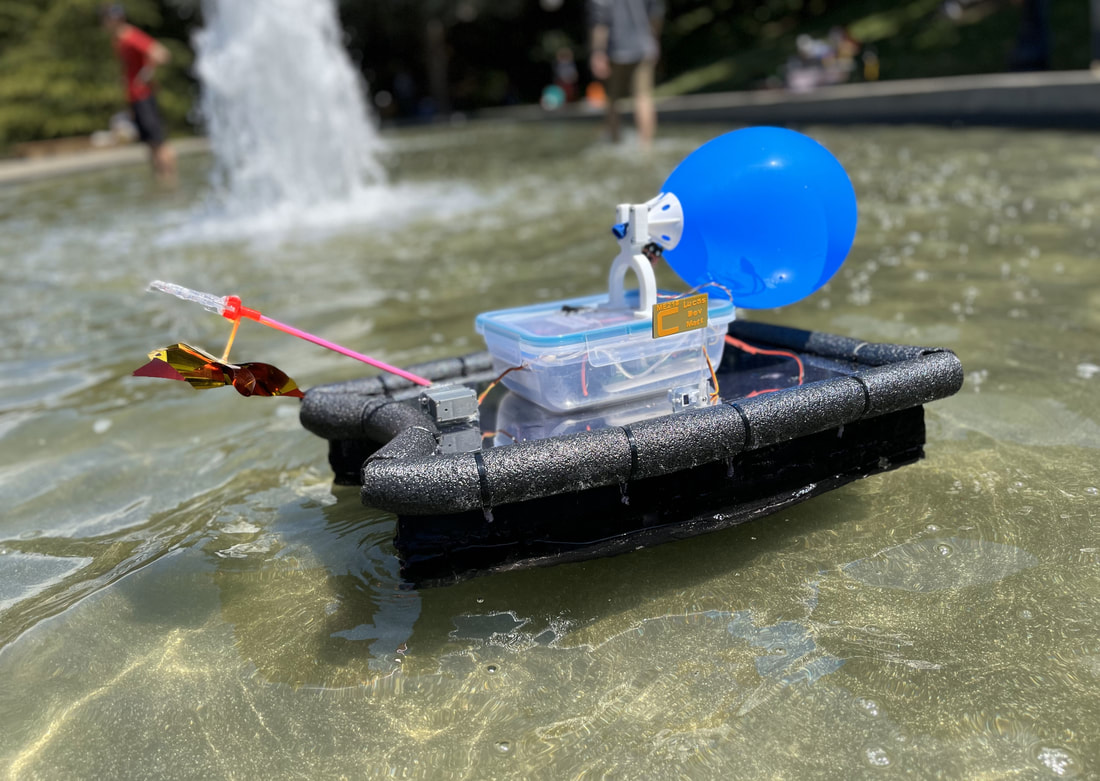
ME218B Final Project
Wheeled robot for final project of Stanford ME218B course.
View ME218B Final project →